
Differences
This shows you the differences between two versions of the page.
| Both sides previous revisionPrevious revisionNext revision | Previous revision | ||
| research:robots [2015/02/20 08:24] – amaldo | research:robots [2026/05/08 07:13] (current) – dkastens | ||
|---|---|---|---|
| Line 1: | Line 1: | ||
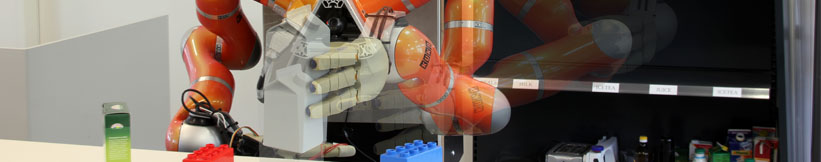
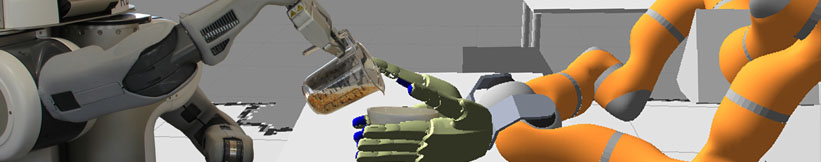
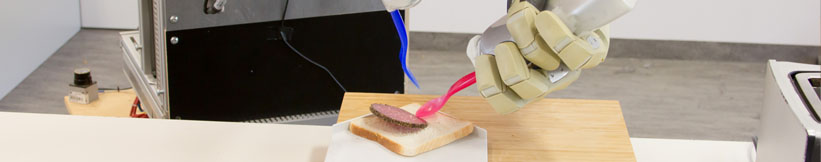
| - | =====Robots in our lab===== | + | =====Robots in our labs===== |
| - | Currently we have three robot platforms in our lab: a PR2, Boxy and a TurtleBot. Boxy is custom built by our group constructed around an omnidirectional base and KUKA-lightweight LWR-4 arms. | + | Currently we have seven robot platforms in our labs: |
| |< 100% 33% 33% 33%>| | |< 100% 33% 33% 33%>| | ||
| - | + | ^ {{ : | |
| - | ^ {{ : | + | ^ [[http://wiki.ros.org/Robots/PR2|Raphael - PR2]] ^ |
| - | ^ [[http://www.willowgarage.com/pages/pr2/ | + | ^ {{ : |
| + | ^ Stretch | ||
| + | ^ {{ : | ||
| + | ^ Tracy ^ ^ ^ | ||
Prof. Dr. h. c. Michael Beetz PhD
Head of Institute
Contact via
Andrea Cowley
assistant to Prof. Beetz
ai-office@cs.uni-bremen.de
Discover our VRB for innovative and interactive research

Memberships and associations:


Social Media:

